
Prof. Bruno Vilhena Adorno
University of Manchester, United Kingdom
Robot modeling and control, constrained manipulation, and dual-quaternion methods.
Google Scholar
University of Manchester, United Kingdom
Robot modeling and control, constrained manipulation, and dual-quaternion methods.
Google Scholar
Embry-Riddle Aeronautical University, USA
Verifiable Adaptive Architectures for Control of Safety-Critical Systems.
Faculty profile
Tecnologico de Monterrey, Mexico
Automatic control, estimation, artificial intelligence, and applied dynamic systems.
Google Scholar
Tecnologico de Monterrey, Mexico
Research strategy, automatic and fault-tolerant control, educational innovation, and leadership in STEM.
Faculty profile
Embry-Riddle Aeronautical University, USA
Interpretable Dynamical Intelligence for Autonomous Navigation, Mission Design, and Decision Support in Cislunar Operations.
Google Scholar
University of Nevada, Reno, USA
Geometric Mechanics, Estimation, and Control for Autonomous Space Systems.
Google ScholarWorking four-day schedule — session times, room names, and placements remain subject to change.
HERO Challenge has two tracks: Robotics and CanSat. Dates will be announced. View the competition programme.
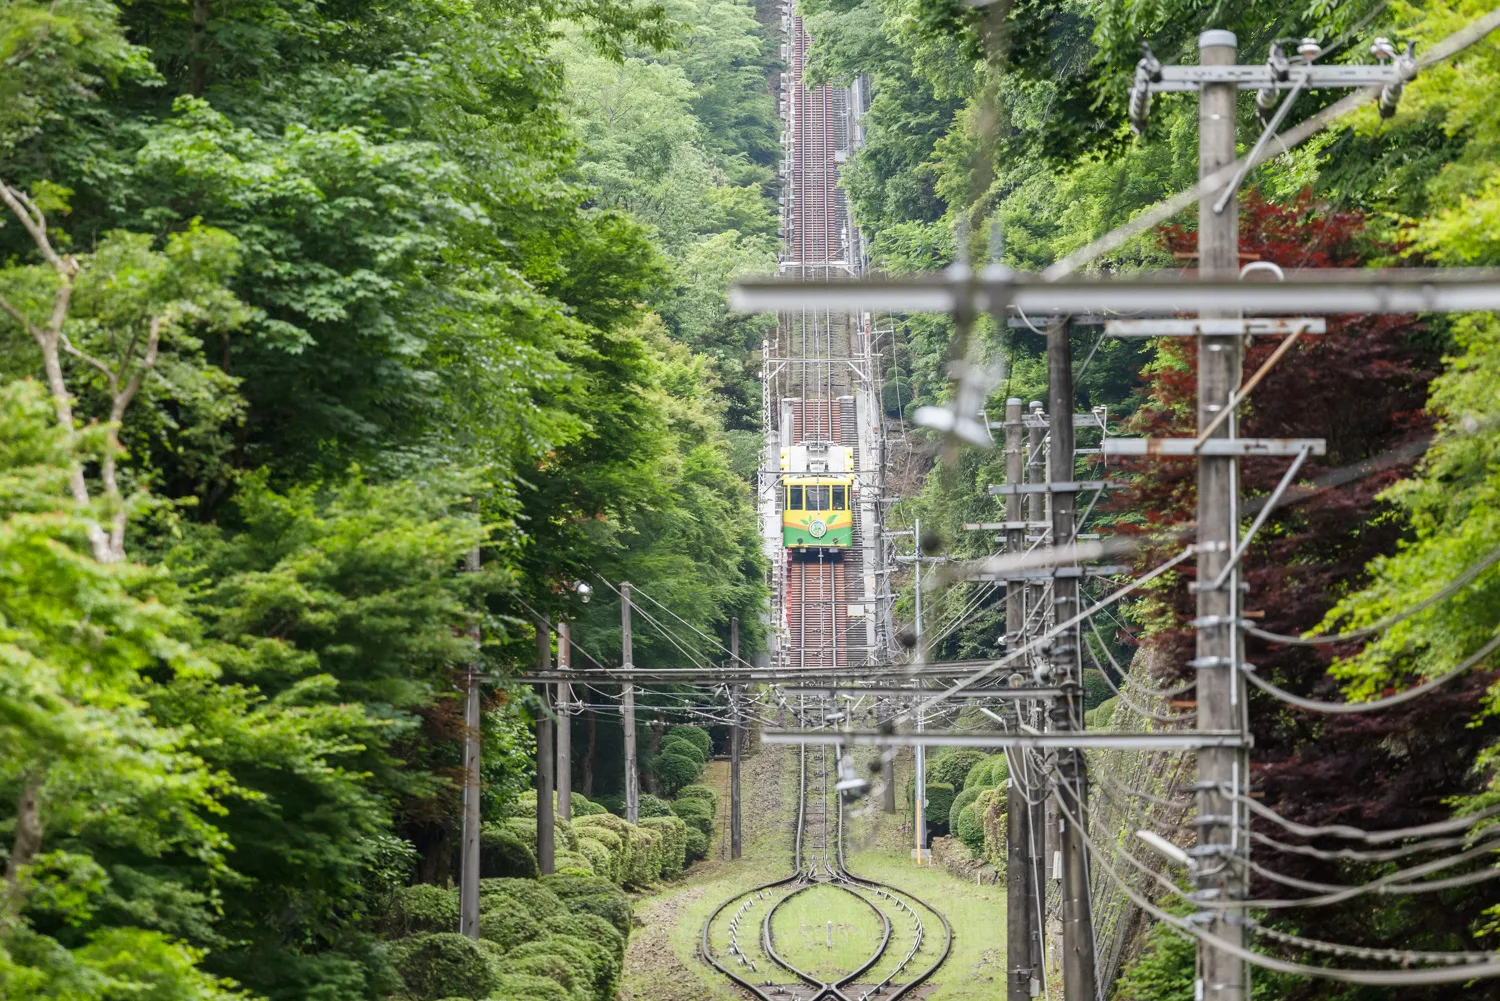
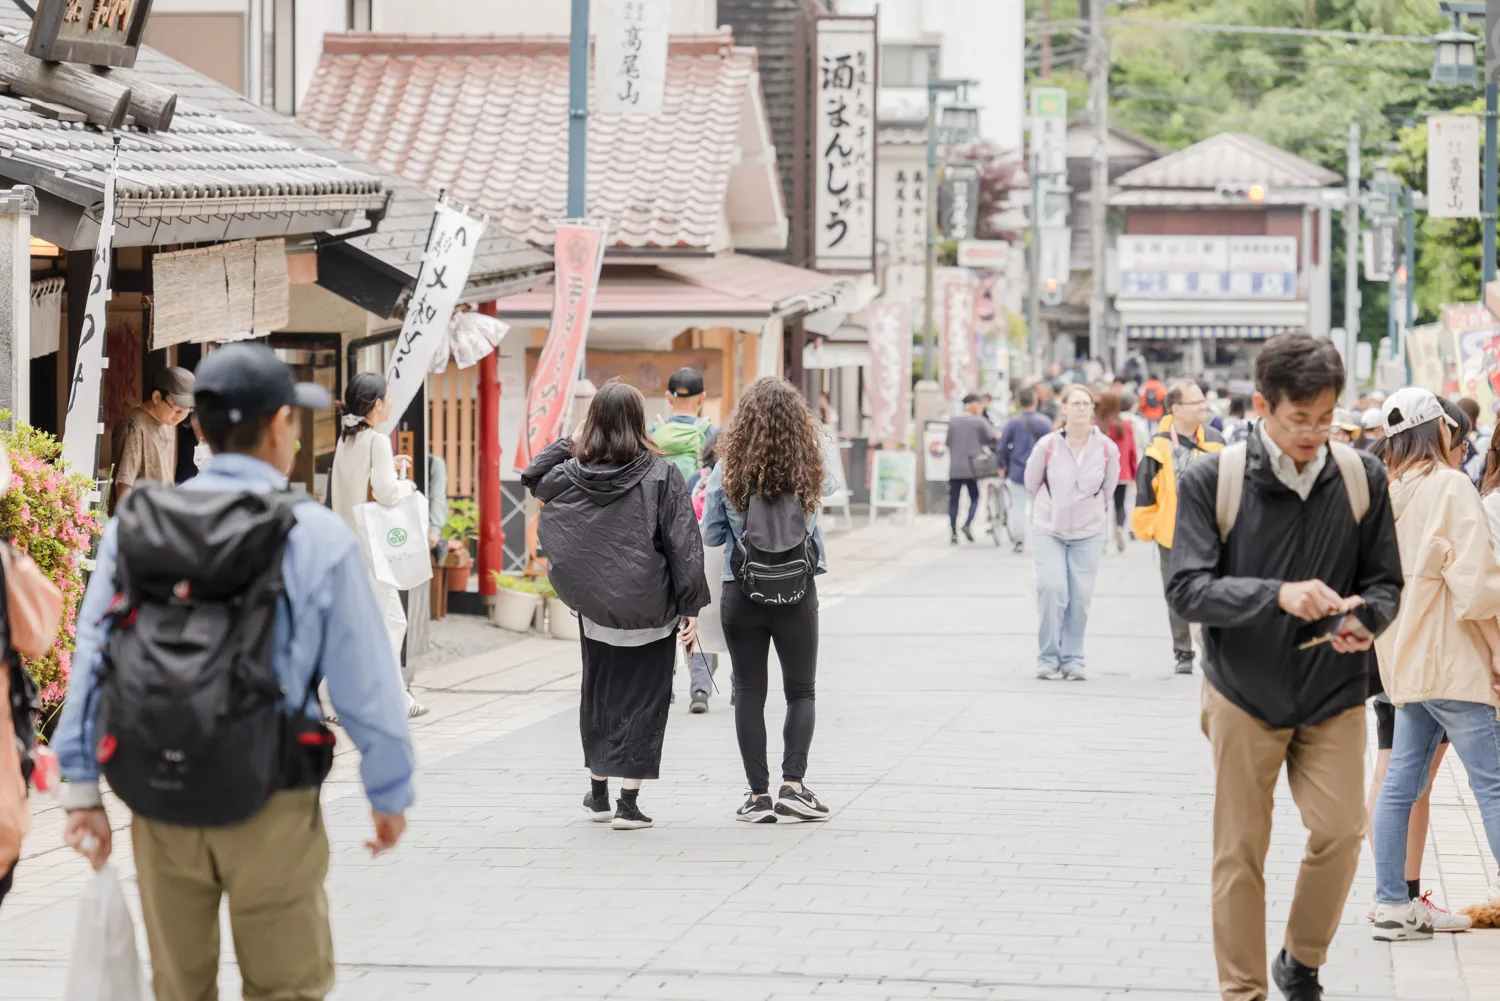
The route, accessible options, lunch venue, transport, any additional cost, and sign-up details will be confirmed later.
Images courtesy of the Hachioji Tourism and Convention Association.