Drone release
An organizer-operated drone carries the stowed CanSat to the release point.
Release. Land. Return.
An autonomous recovery mission: a CanSat is released by an organizer-operated drone, descends under its recovery system, deploys after landing and travels over the ground toward a designated target.
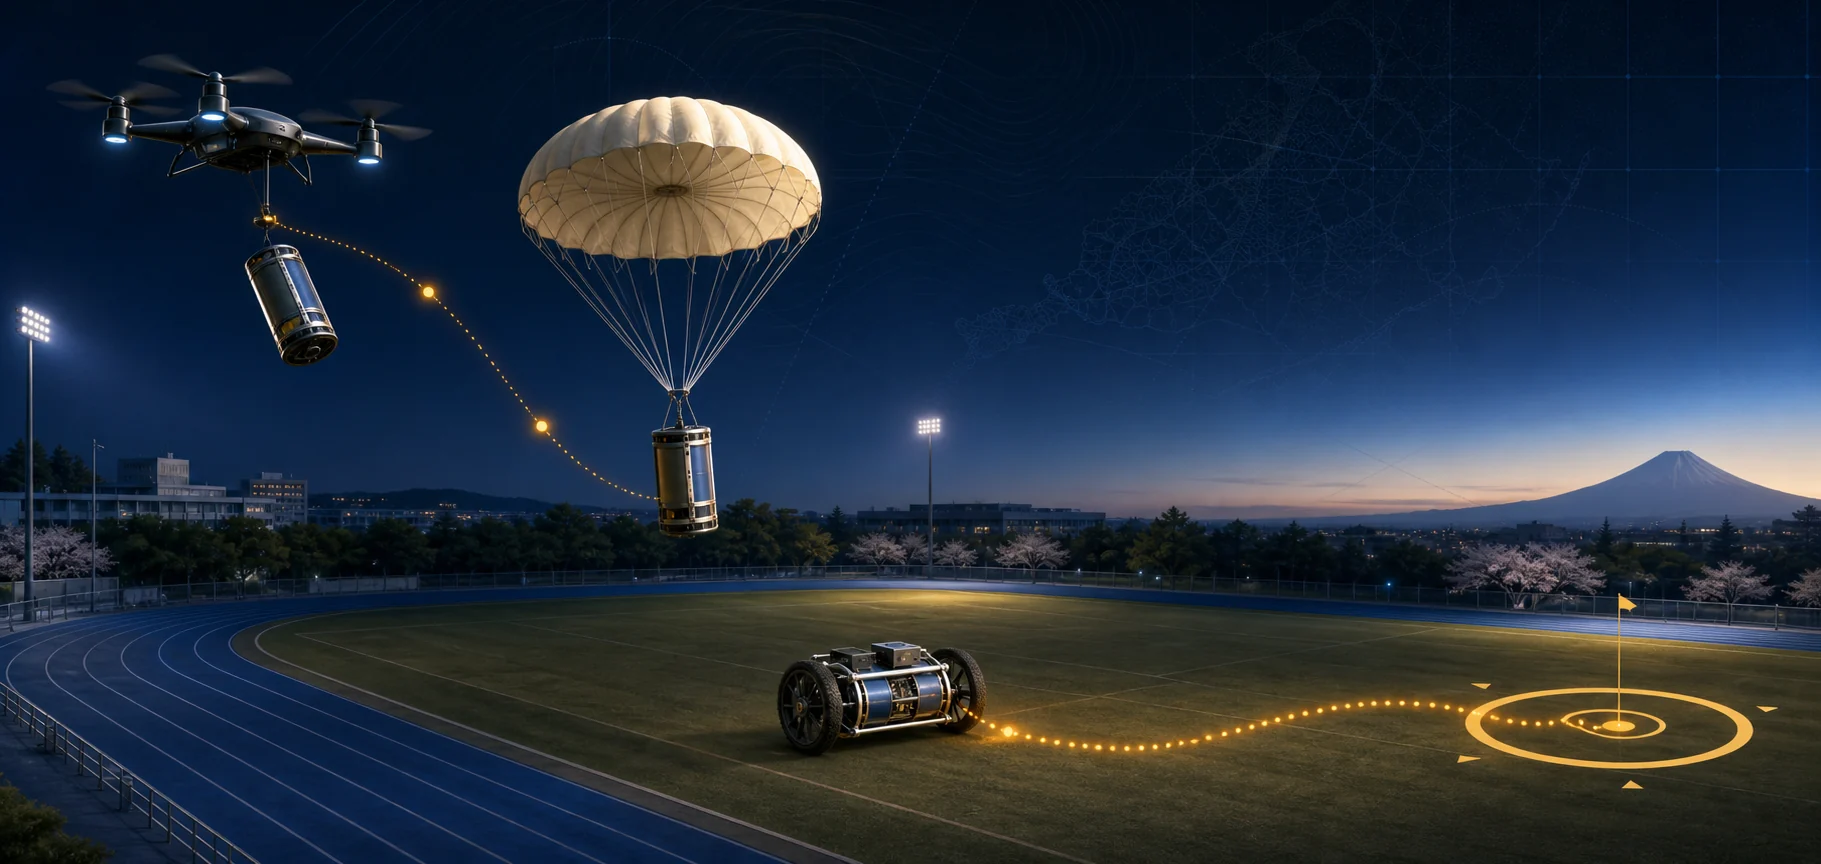
Teams integrate descent recovery, landing detection, post-landing deployment and terrestrial navigation in one compact system.
Release height, field geometry, timing and scoring will be specified in the official rulebook and Edition Annex.
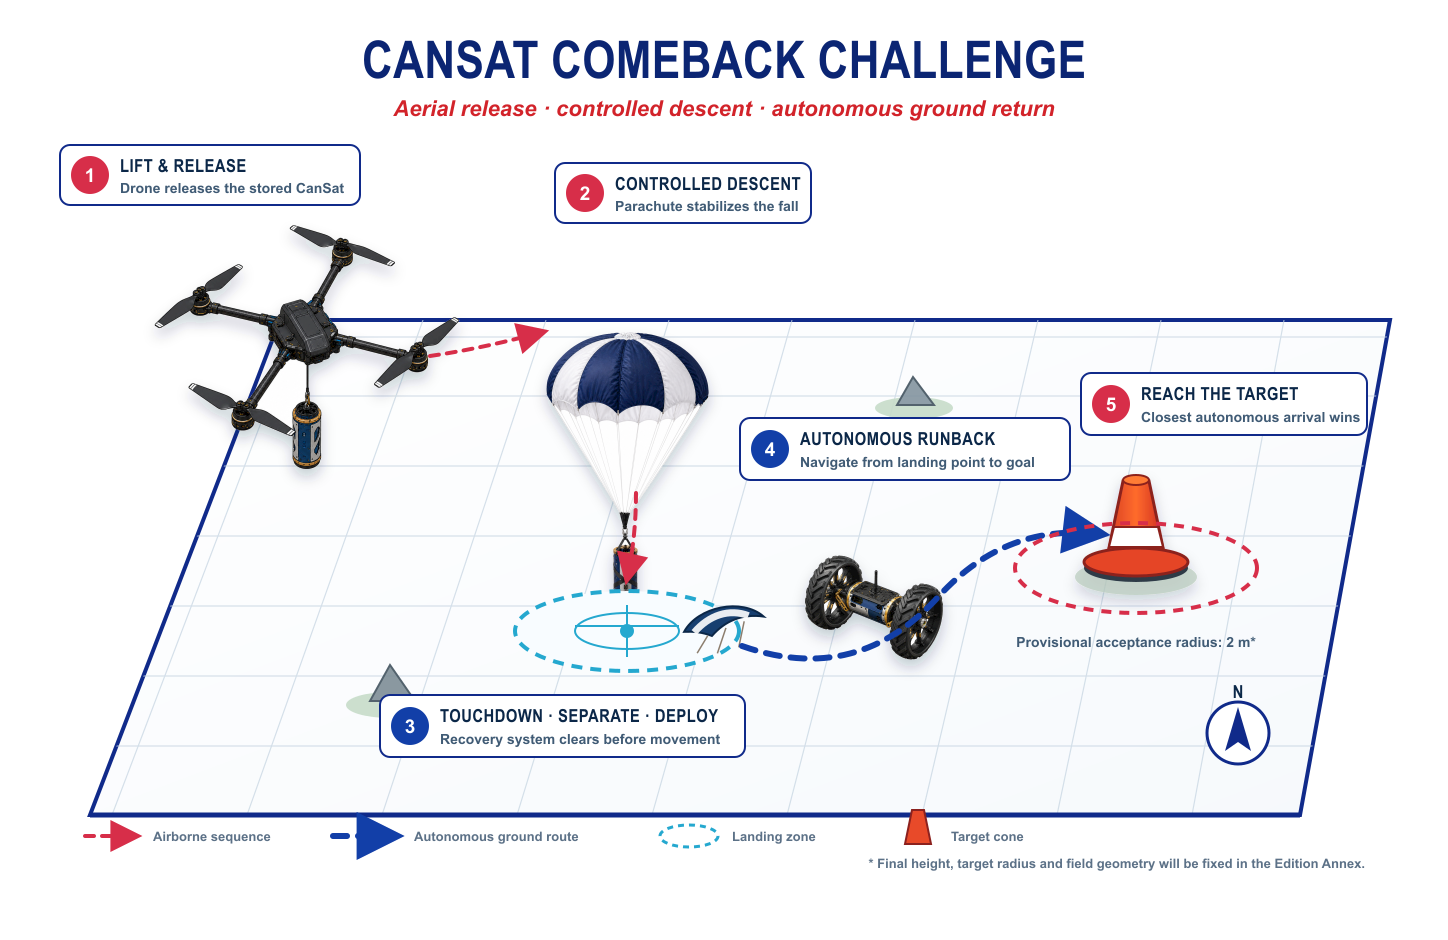 Full-size map
An organizer-operated drone carries the stowed CanSat to the release point.
The recovery system stabilizes the descent and limits landing impact.
The CanSat detects touchdown and transitions to its ground-travel configuration.
The vehicle navigates from the landing point toward the designated target.
The vehicle's final position relative to the target is recorded for scoring.
Teams may balance mass, deployment reliability, stability and terrain handling using different ground-mobility designs.
Compact and lightweight, but more sensitive to balance and touchdown orientation.
More stable and terrain-capable, with added mass and mechanical complexity.
Alternative designs may be accepted if they satisfy the final size, mass, safety and field requirements.
The rulebook and Edition Annex will define size and mass limits, the release-system interface, field conditions, safety checks, scoring and registration.